Warning
You are reading an old version of this documentation. If you want up-to-date information, please have a look at 1.1 .Plugin release 1.0
Version 1.0.1
Bug Fixes
Global variable EYE1Pos components
Previously, the orientation of the global variable was described as a rotation vector with a prefixed orientation of RX = 180°. The transformation from roll, pitch and yaw coordinates into a rotation vector was performed as follows
The EYE+ sends the coordinates p[X,Y,0,0,0,RZ] (roll, pitch and yaw)
The plugin transforms the roll, pitch and yaw coordinates into a rotation vector: p[X,Y,0,rx,ry,rz].
By transforming the coordinates into a rotation vector, it was not possible to retrieve the true RZ value. This was an issue in case the robot configuration p[X,Y,0,180°,0,RZ] was not suitable for the application.
Now, the global variable EYE1Pos is equal to: p[X,Y,Z,0,0,RZ], where X, Y, RZ are the coordinates sent by EYE+. RZ is in radian. As the robot is expecting a rotation vector, you cannot directly move to the position. You at least have to add the 0-position of the robot as presented below.
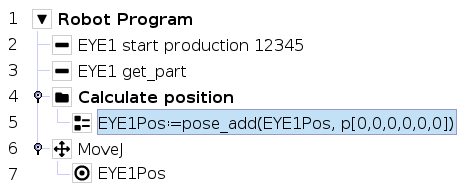
Fig. 31 Position correction before Move
Note
Refer to section EYE1Pos to get more information about the global variable EYE1Pos.
Main new features
Multi-tasking behavior
It is now possible to send two commands in parallel through the UR program. See the example below.

Fig. 32 Example of multithreading used to stop the production in reaction to a change in the DO[1] value